Search result · source text not verified
Hiring freelancers who love to write about romance story
Hate to say it, but Talex, and Timothy's new venture, Deepreach.ai, is a scam. It doesn't exist, but the "founder""Timothy (Tiany) Li may.
Apply to become a DeepReach Data Partner. After an offline interview and invitation, review matched work before completing contracts and hardware setup.
We could read the site overview, but could not identify its products or services.
No matching products or features.
Search result · source text not verified
Hate to say it, but Talex, and Timothy's new venture, Deepreach.ai, is a scam. It doesn't exist, but the "founder""Timothy (Tiany) Li may.
Search result · source text not verified
Year later when it was time for reviews the new GM gave me an absolutely raving review. ... DeepReach? bagfnzac. OP •. 1y ago.
Search result · source text not verified
DeepReach.ai provides expert-driven evaluation as a service for enterprise AI. It features real-world, dynamic benchmarks with live data updates and ...
Search result · source text not verified
A buyer-side brief on why deepreach.com matters for DeepReach AI, from trust and email deliverability to SEO and confidential acquisition ...
No feedback found.
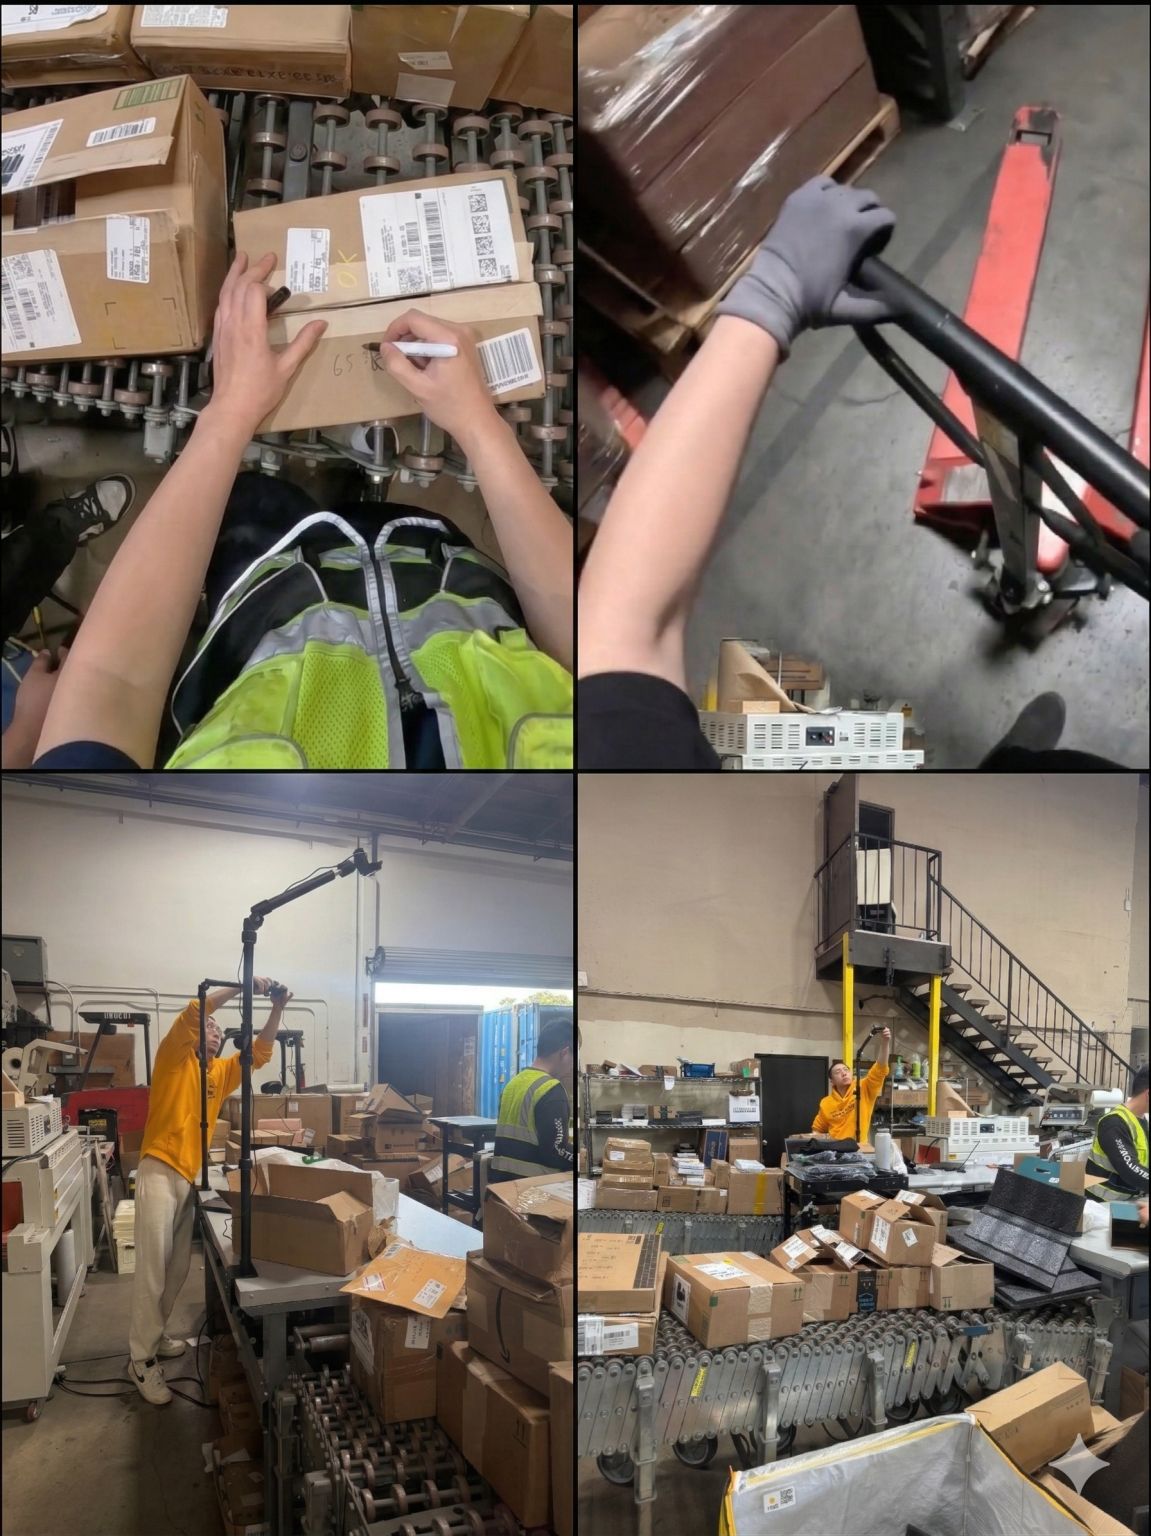
Real-World Ground Truth: Capturing the Nuance of Industrial Dexterity. Sim-to-real isn't just a technical challenge, it’s a data acquisition challenge. To move beyond laboratory prototypes, robotic models require exposure to the "messy" reality of actual work environments. We specialize in capturing high-fidelity, ego-centric (first-person) data directly from the frontlines of US-based warehouses, manufacturing plants, and agricultural sites. The Value of Our Data Acquisition: 1. Unstructured Reality: We go where lab cameras can’t. Our datasets capture the high-variance lighting, complex occlusions, and diverse object interactions inherent to real-world industrial workflows. 2. The Manipulation Edge: By focusing on the "last inch" of interaction through ego-vision, we provide the granular hand-object telemetry necessary to train models on production-grade dexterity. 3. Localized Context: Data captured within authentic US infrastructure, providing the specific environmental cues, packaging standards, and operational logic required for localized deployment. We provide the high-fidelity visual foundation that allows models to transition from general perception to task-specific physical mastery. Interested in our data acquisition capabilities or looking for specific industrial manipulation sequences? Let’s connect. #Robotics #DataAcquisition #ComputerVision #EgoCentric #IndustrialAI #Dexterity #EmbodiedAI #SimToReal #TrainingData #LogisticsAutomation
Landing page unavailable: the ad source did not supply a destination URL.
DeepReachAI Joins the NVIDIA Inception Program!! We’re excited to share that DeepReach has been selected into the NVIDIA Inception Program. This milestone comes at a meaningful moment for us. In January 2026, our ARR doubled, driven by growing demand for real-world robot deployment, tele-operation, and production-grade execution. It’s a strong signal that the market is ready to move beyond demos, and into robots doing real jobs. As we enter the next phase, our focus shifts into deep technical accumulation. We’re deploying robots into real production environments and training them to execute concrete actions and task modules. Through continuous in-the-wild data collection, tele-ops, and model iteration, we’re strengthening robots’ ability to generalize tasks and scale reliably across sites. We’re grateful for the intense effort and support from our team over the past few weeks, and for the trust and guidance from our key investors and partners who continue to back this journey. Being part of NVIDIA Inception reinforces our conviction that the future of robotics will be built at the intersection of deployment, data, and real-world execution. More to come as we keep building. #Robotics #PhysicalAI #NVIDIAInception #AIinProduction #RobotDeployment #Teleoperation #DeepTech
Landing page unavailable: the ad source did not supply a destination URL.
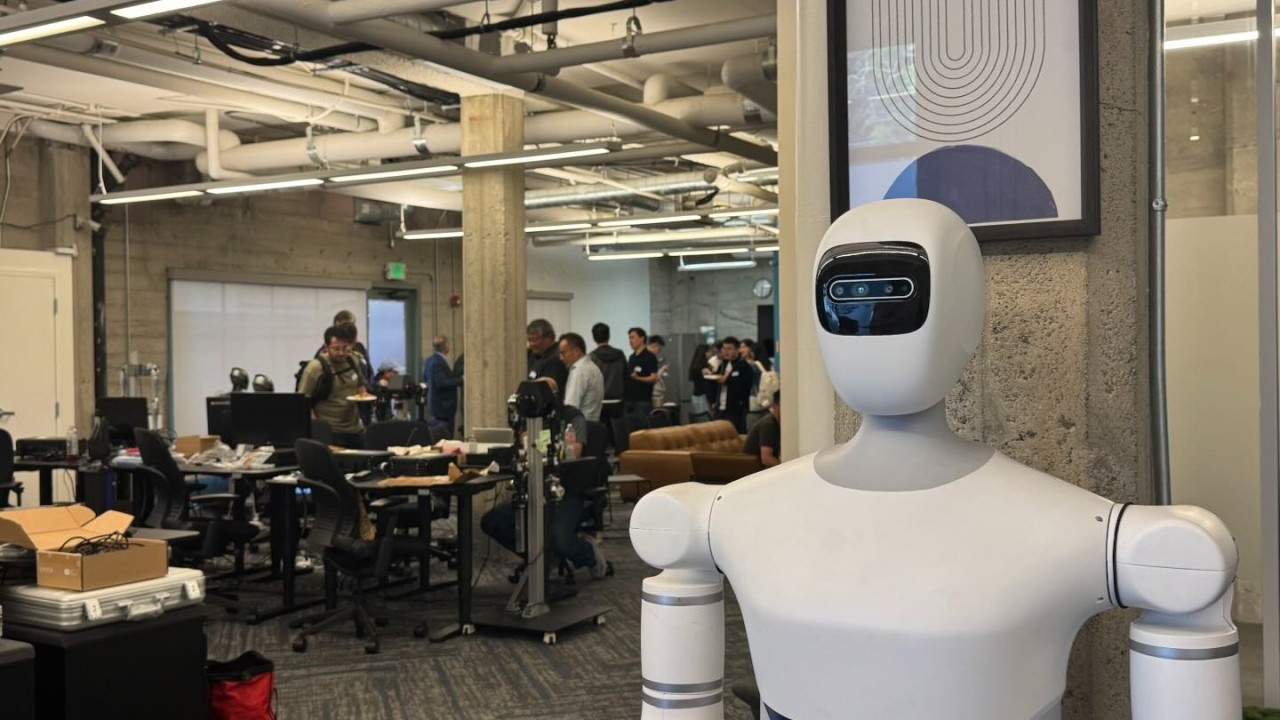
The "GPT moment" for robotics won't come from bigger models, it will come from a unified data language for the physical world. Great night in Palo Alto debating the "Dirty Data" problem with the best from NVIDIA, OpenAI, xAI and Meta. We took a deep dive into NVIDIA’s EgoScale-the conclusion? Scaling egocentric (POV) data is the only way to bridge the gap between pixels and action. At Deepreach.ai, we aren't just collecting data; we are building the infrastructure to encode real-world interaction into something models can finally "understand." Check out the full recap below. 👇 #PhysicalAI #SpatialAI #Robotics #EgoScale #DeepTech #MachineLearning #WorldModel #DeepReach
Landing page unavailable: the ad source did not supply a destination URL.
Modified Source ↗
Modified Source ↗
Modified Source ↗
Modified Source ↗
Modified Source ↗
Modified Source ↗
Modified Source ↗
Modified Source ↗
Observed website styles · partial · Nov 12, 2026
primary · inferred
Source ↗accent · inferred
Source ↗primary · inferred
Source ↗accent · inferred
Source ↗background · inferred
Source ↗text · inferred
Source ↗text · inferred
Source ↗text · inferred
Source ↗border · inferred
Source ↗text · inferred
Source ↗text · inferred
Source ↗text · inferred
Source ↗border · inferred
Source ↗border · inferred
Source ↗background · inferred
Source ↗background · inferred
Source ↗Disclaimer: These samples are not verified official brand guidelines or a complete palette. Previews use system fonts; font licensing, reuse and redistribution rights are unverified. Font URLs are evidence only. Actual rendering and loaded fonts may differ; displayed font names may be simplified.
CSS declarations only; browser rendering, cascade, active theme, loaded fonts and official brand guidelines have not been verified. Generated font aliases are normalized for display; exact declarations remain in cssFamily. Colors are semantic declaration samples converted to sRGB, not an exhaustive palette. Font asset URLs are evidence only; license and redistribution rights are unknown.